News
ASPIRE Research on Digital Twin-Assisted Agricultural Robot Navigation Presented at IEEE CAFE 2026
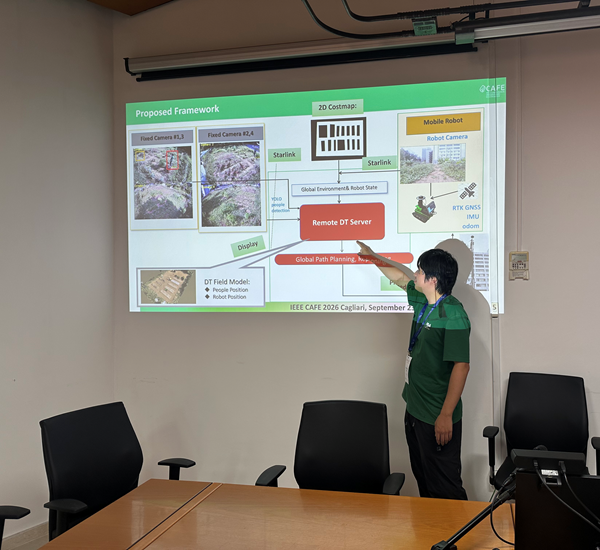
Zhenghong Jiang presented ASPIRE research on digital twin-assisted distributed path planning and autonomous navigation for mobile agricultural robots at IEEE CAFE 2026, held in Cagliari, Italy, from September 23 to 25, 2026.
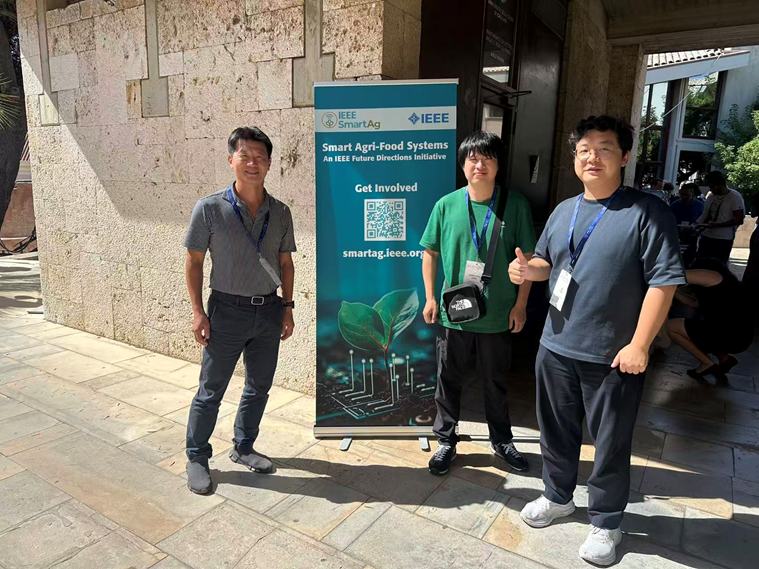
From September 23 to 25, 2026, Zhenghong Jiang participated in IEEE CAFE 2026 in Cagliari, Italy, where he presented the research titled “Digital Twin-Assisted Distributed Path Planning and Autonomous Navigation for Mobile Agricultural Robots.”
The research focuses on the application of digital twin technology to distributed path planning and autonomous navigation for mobile robots in agricultural environments.
The presentation provided an opportunity to share the research with the international community and exchange ideas on the application of digital twin technologies to smart agriculture and autonomous robotic systems.